

Googol technology, starting from HKUST in 1999, is the first high-tech company in the Asia Pacific region specializing in R&D, production, marketing, and assisting regulators and motion control systems. Googol technology provides a platform for technological innovation for machine manufacturers, focusing on research in four base technologies - motion control technology, servo drive technology, computer vision technology, and mechanical design optimization. With deepened international and national cooperation, combining production and research, and actively cultivating system integrators, Googol technology's motion control products and systems are applied in a wide range of industries, such as microelectronics, robotics, CNC machine tools, electronic processing and testing, printing, packaging, production automation, and other industrial control uses.
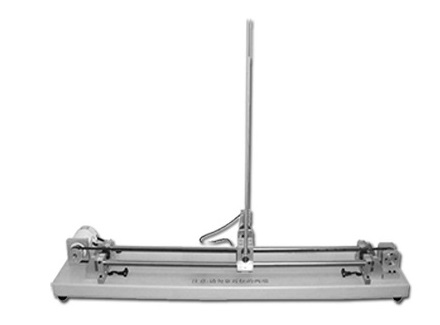
The inverted pendulum system is an unstable nonlinear system, an ideal experimental platform for teaching control theories and conducting various control experiments. Many abstract control concepts, such as stability and controllability of a control system, can be visually displayed through the inverted pendulum system. In addition to educational purposes, an inverted pendulum is also a research area for many researchers of modern control theories. Through continuous research on new ways to control the inverted pendulum, researchers have developed new control methods and applied them to high-tech areas such as aerospace engineering and robotics, thanks to the system's features, such as multi-order high instability, non-linearity, and strong coupling. The products of the linear inverted pendulum series developed by Googol Technology adopt an open control solution and a modular experimental platform. With the linear motion module as a base platform, it is easy to build more than 10 teaching and experimentation control platforms, meeting various teaching and research needs in control.
Experimentar:
● Correction of the root locus
● Correction of PID
● Correction of frequency domain
● State feedback control
● Mechanism modeling and stability analysis
● Open loop frequency response test
Technical Specifications
Function
Description
Valid travel distance
720mm
Max. movement speed
6000mm / s
Friction system between Dolly and sliding bar
<0.02N ▪ s / m
Dimensions
1000 x 220 x 150 mm
Peso
<15kg
Modelos
Model No.
Descriptiones
GLIP2001
Inverted linear pendulum in one stage
GLIP2002
Two-stage linear inverted pendulum
GLIP2003
Three-stage inverted linear pendulum
GLIP2004
Four-stage linear inverted pendulum
GLIP2011
Single-stage inverted linear pendulum
GLIP2012
Two-stage linear inverted pendulum with flexible joint
More information:
Includes:
** 2-year warranty.
** Discounts for the sale of two or more Robots educativos.
** Metrological calibration certificate for Robots educativos.